Vernia Plan a pilot

Robot hands learn from human ones.

We collect real-world manipulation data with Grip One and View One, or with the rig you already train on.

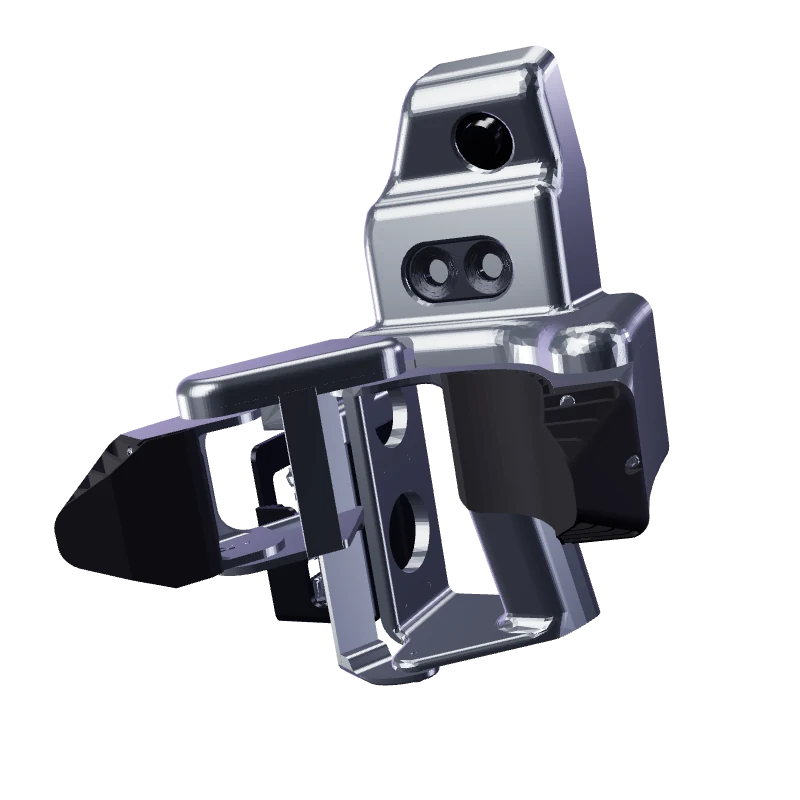
Grip One, Vernia's handheld gripper
  • Wide RGB cameraSony IMX219, 8 MP, 160° field of view
  • Stereo pair2 × OV9281, 1 MP mono, global shutter
  • IMUBosch BMI270, 6-axis
  • Jaw encoderAS5600 magnetic, 12-bit
  • Force sensorThumb-tip FSR, 16-bit ADC
  • Record buttonTactile switch with status LED

Drag to turn. Tap to grip.

Grip One

Reserve now
  • Stereo pair2 × OV9281, 1 MP mono, global shutter
  • Wide RGB cameraSony IMX219, 8 MP, 160° field of view
  • IMUBosch BMI270, 6-axis
  • Recorder and batteryRaspberry Pi, 64 GB, 10,000 mAh
  • Record buttonTactile switch with status LED
  • Adjustable strapFits most heads

Drag to turn.

View One

Reserve now

Put the fruit in the bowl.

Pick up both and drop them in the bowl. Grip One records you the way it records our operators.

Loading Grip One

Move over the table to start recording.

Jaw width0 mm
Grip force0.0 N

Your task, on the hardware you train with.

  • Home kitchens
  • Tailoring shops
  • Corner stores
  • Repair benches
  • Restaurant prep lines

Robots fail in rooms they have never seen.

We record in real homes and shops across Indian cities, where layouts, light and objects change from door to door. Every person who records signs up and is paid.

Some sites we keep back and never sell as training data, so you can test a dataset or a policy somewhere it has not been.

Every lot arrives with its numbers.

Yield
How many episodes passed, and why the rest failed.
Tracking
Pose error for every episode.
Variety
How many places, people and objects the lot covers.
Consent
A signed record for every person on camera.
Format
LeRobot, RLDS or MCAP, or your own schema.

Plan a pilot.

Tell us who you are and what you want to collect. We reply with a plan and a price.

team@vernia.in+91 83029 52133
I'm interested in